Nick Bryant

Software.
Systems.
Worlds.

I build things from the first idea to the working product.
Explore the work ↘

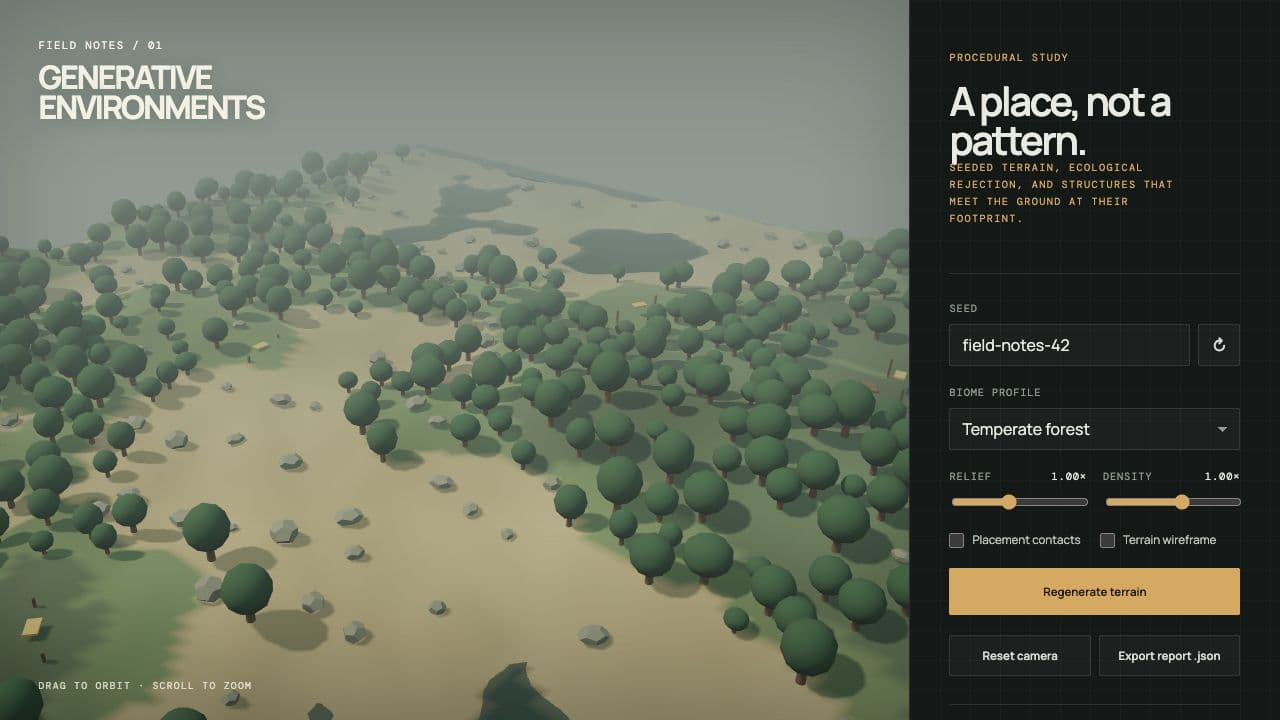
Conceptual terrain study of an imagined generative world

01 / An engineering atlas

02Interactive work

Generative worlds

Games, authoring systems, and small experiments where procedural structure meets deliberate worldbuilding.

Conceptual landscape cross-section from desert mesas to alpine peaks
Concept study / Terrain, rules, inhabitation
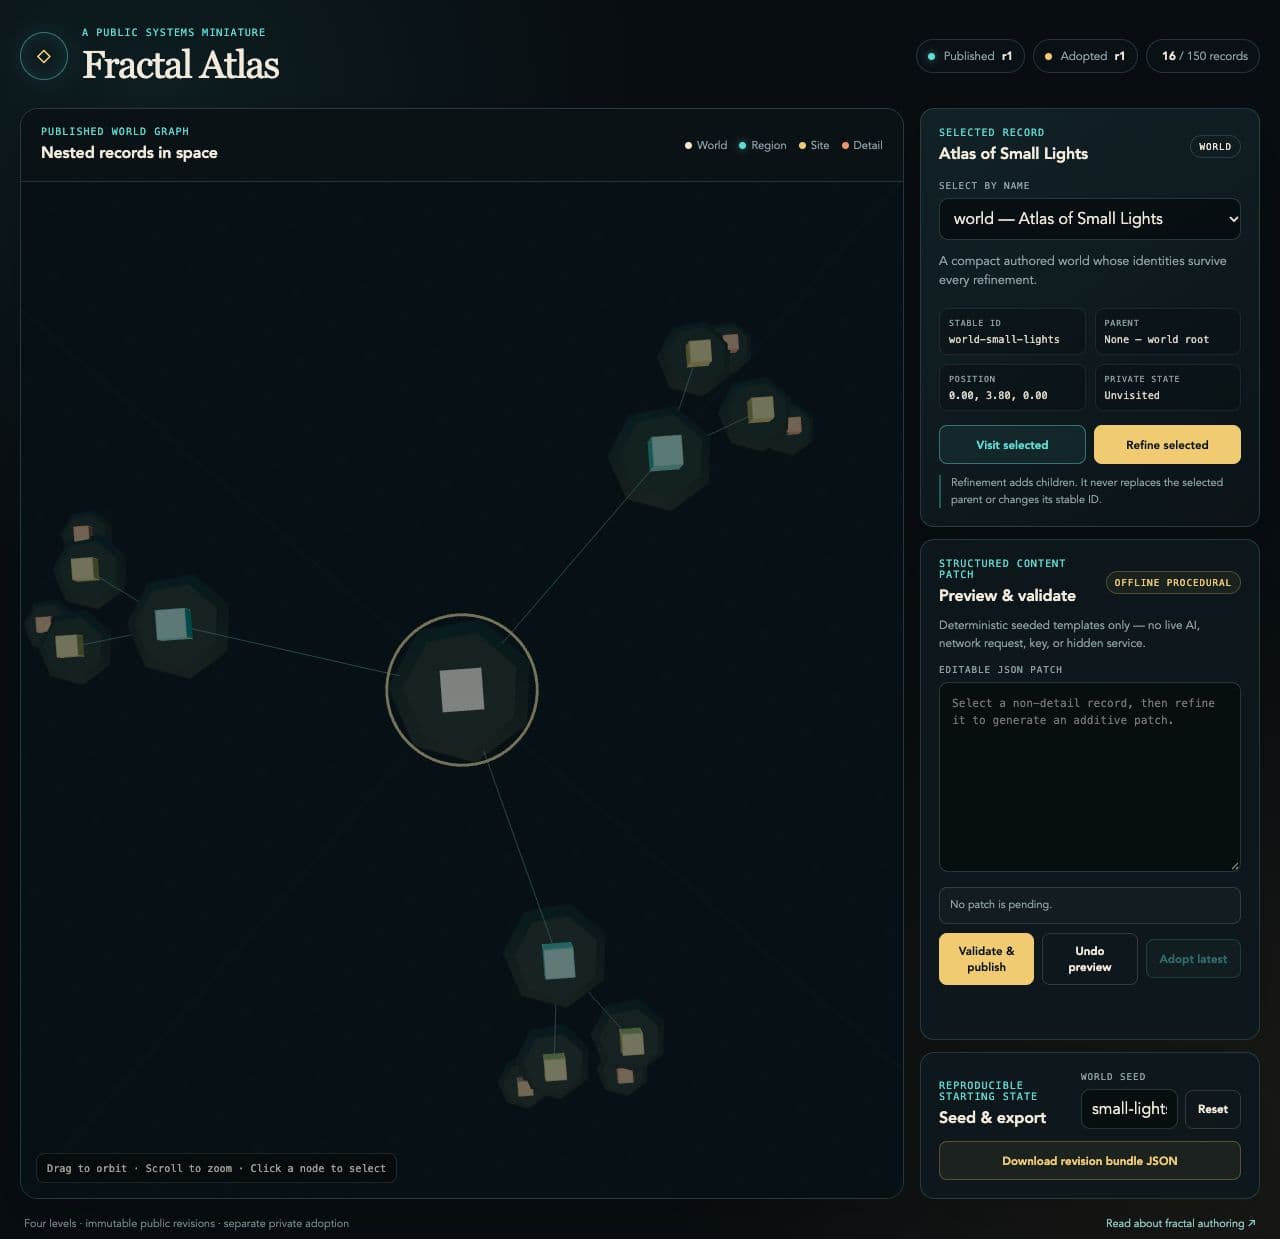
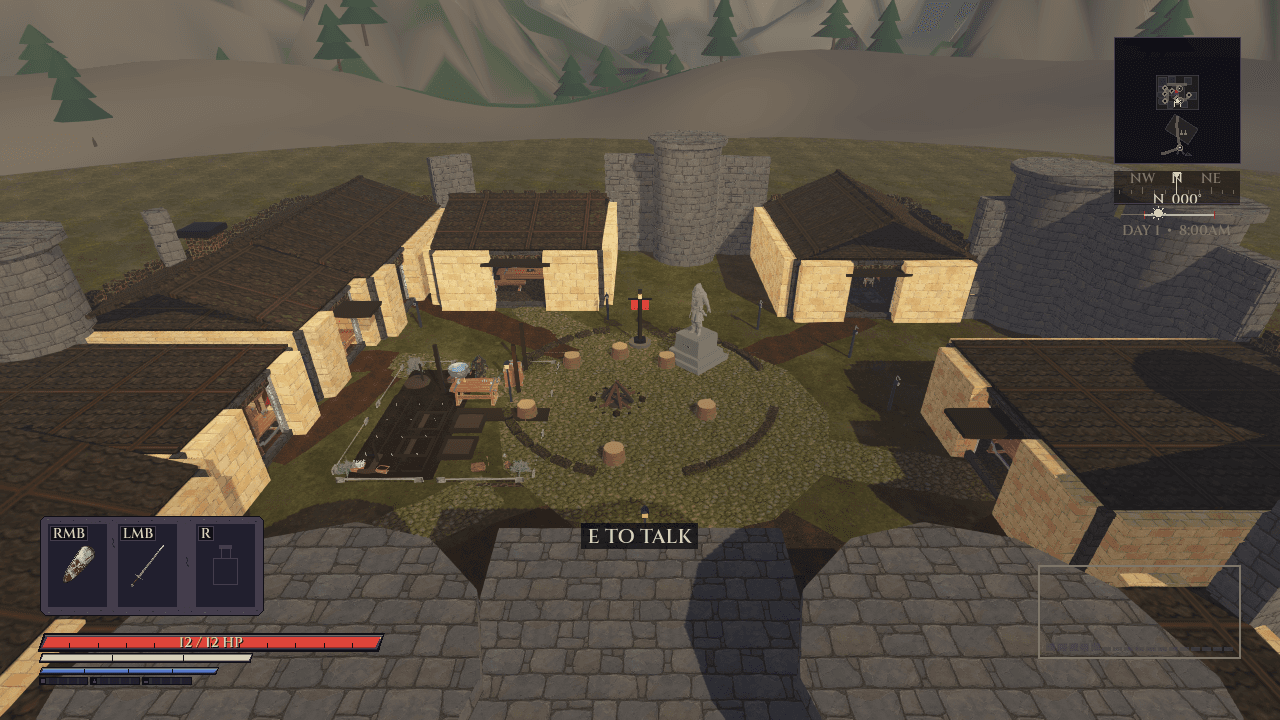
The Lower Worlds project screenshot

01 / Field study

The Lower Worlds

Generative authoring · TypeScript / React / Three.js

An experimental generative-authoring system in TypeScript, React, and Three.js. Models and people define the world, schemas validate and version it, and deterministic rules run the game while player progress stays private.

Explore the architecture

The authoring stack separates intent, validated schema, versioned world definitions, and deterministic runtime state so generated content can remain inspectable.

System plate / 04

The Lower Worlds · architecture study

Illustrative assembly

An exploded isometric illustration of software architecture showing the intent, schema, world, and runtime layers of The Lower Worlds software architecture.

World. Versioned, reusable definitions preserve a coherent world across play.

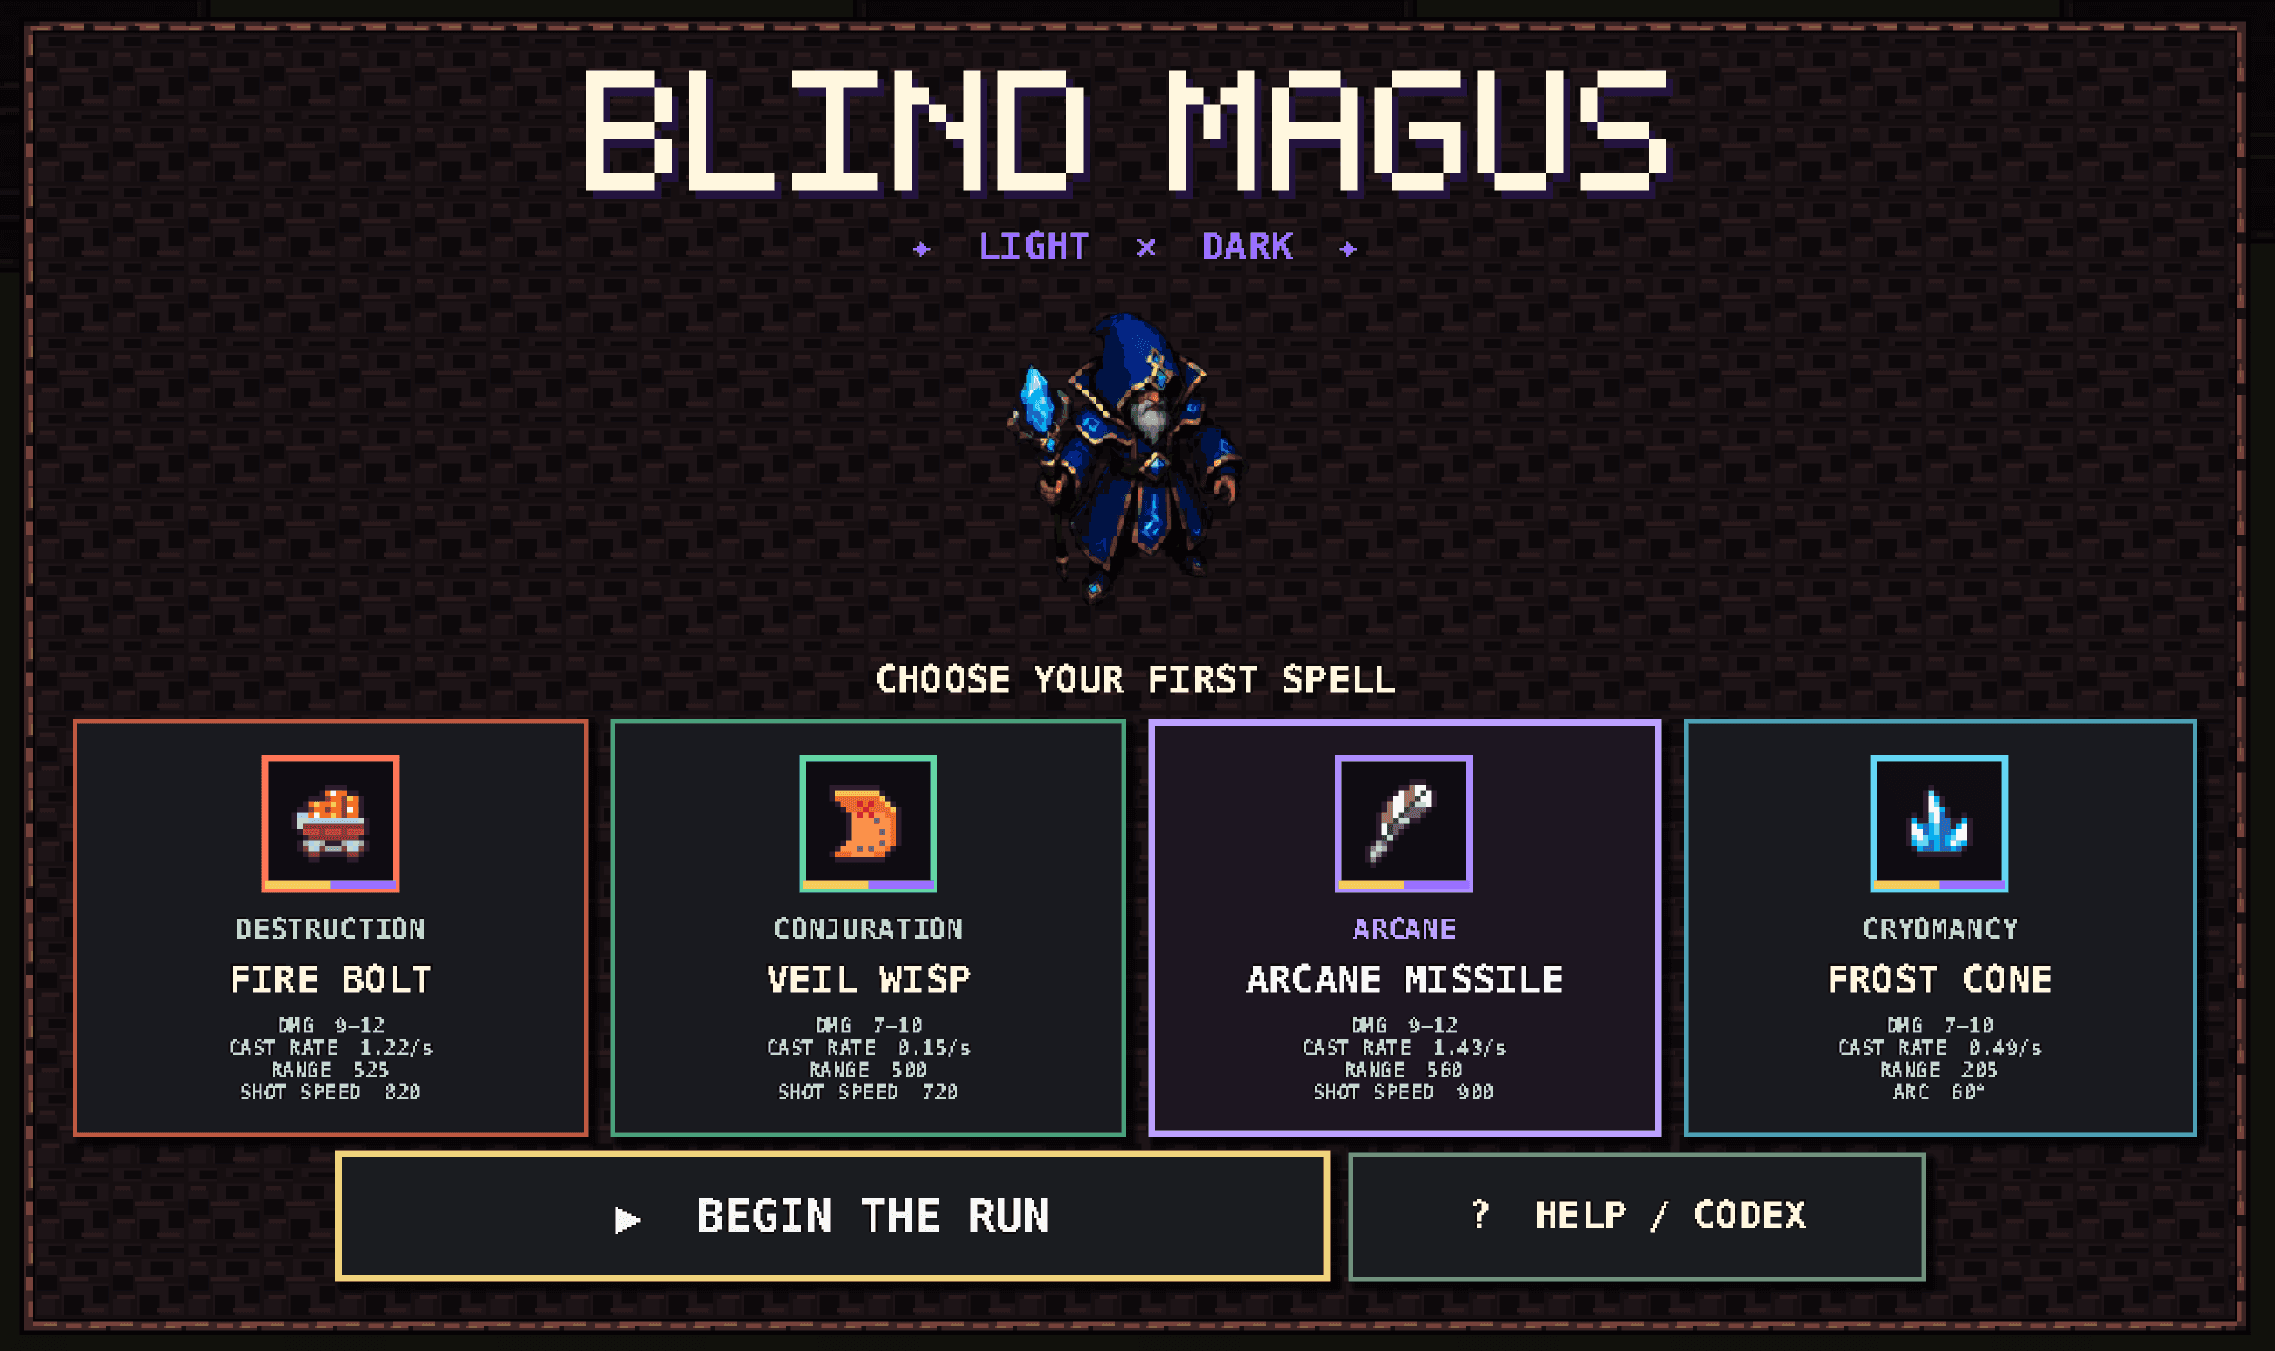
Blind Magus project screenshot

03 / Field study

Blind Magus

Released action game · Independent

A released action game built around combining spells into new effects.

The Lower Worlds: Awakening project screenshot

06 / Field study

The Lower Worlds: Awakening

Creator and engineer · Playable prototype

A third-person dungeon adventure in Godot 4.7: prepare at Highbridge, explore the ruins below, and choose when to return to defend the garrison. Typed GDScript, physical puzzles, persistent progression, and rendered gameplay verification.

Chapter 02 / Applied intelligence

Agents &
systems

Local-first tools that make model work inspectable, bounded, and useful in the physical or commercial world.

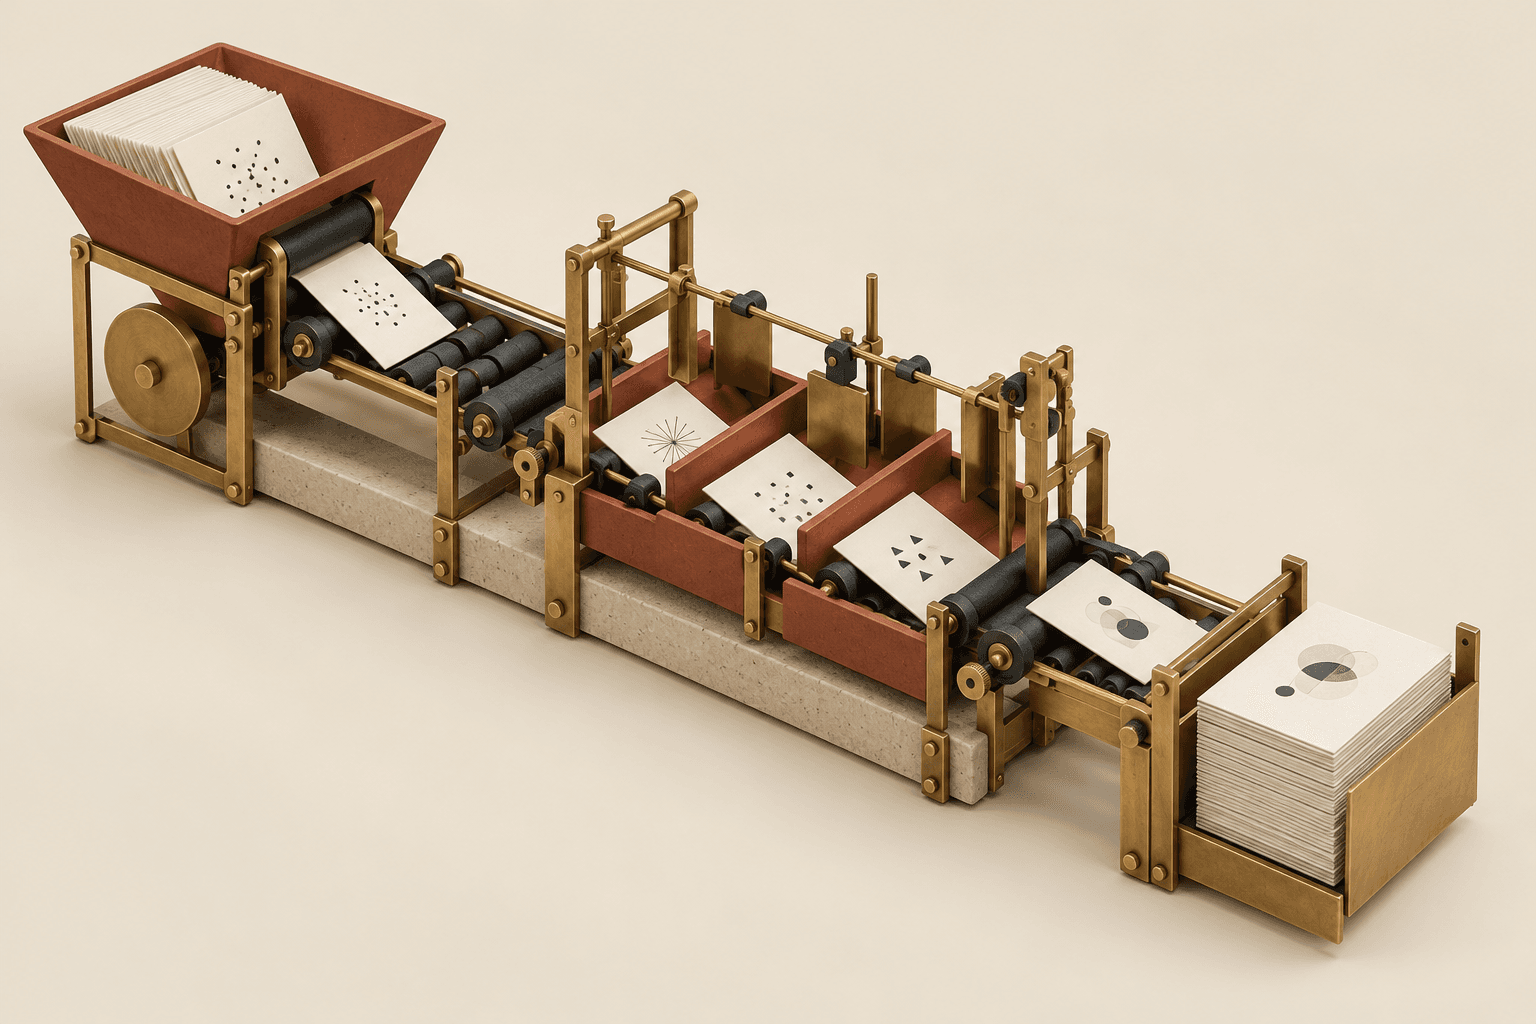
Conceptual study of a speculative workshop machine
Conceptual study / Not actual hardware
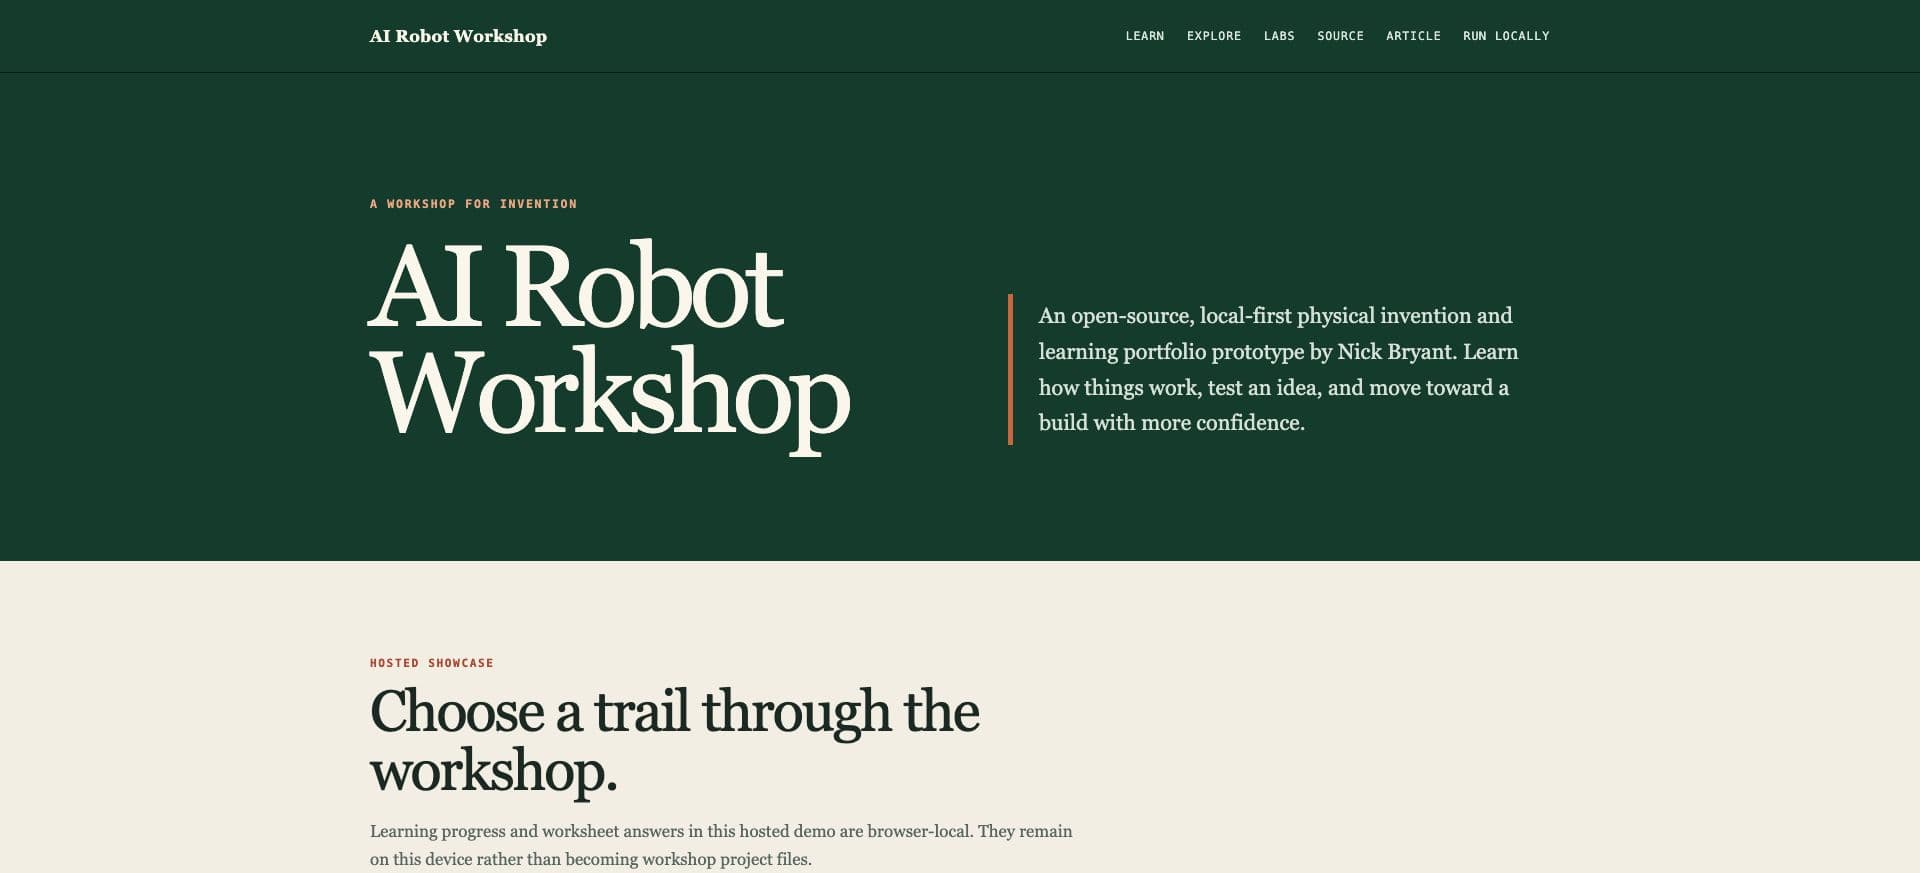
AI Robot Workshop project screenshot

01 / Working system

AI Robot Workshop

Open source · Local-first agent workflow

Turns agent conversations into inspectable plans, firmware, parts records, bounded models, and bench observations. The documented hardware routes remain unbuilt.

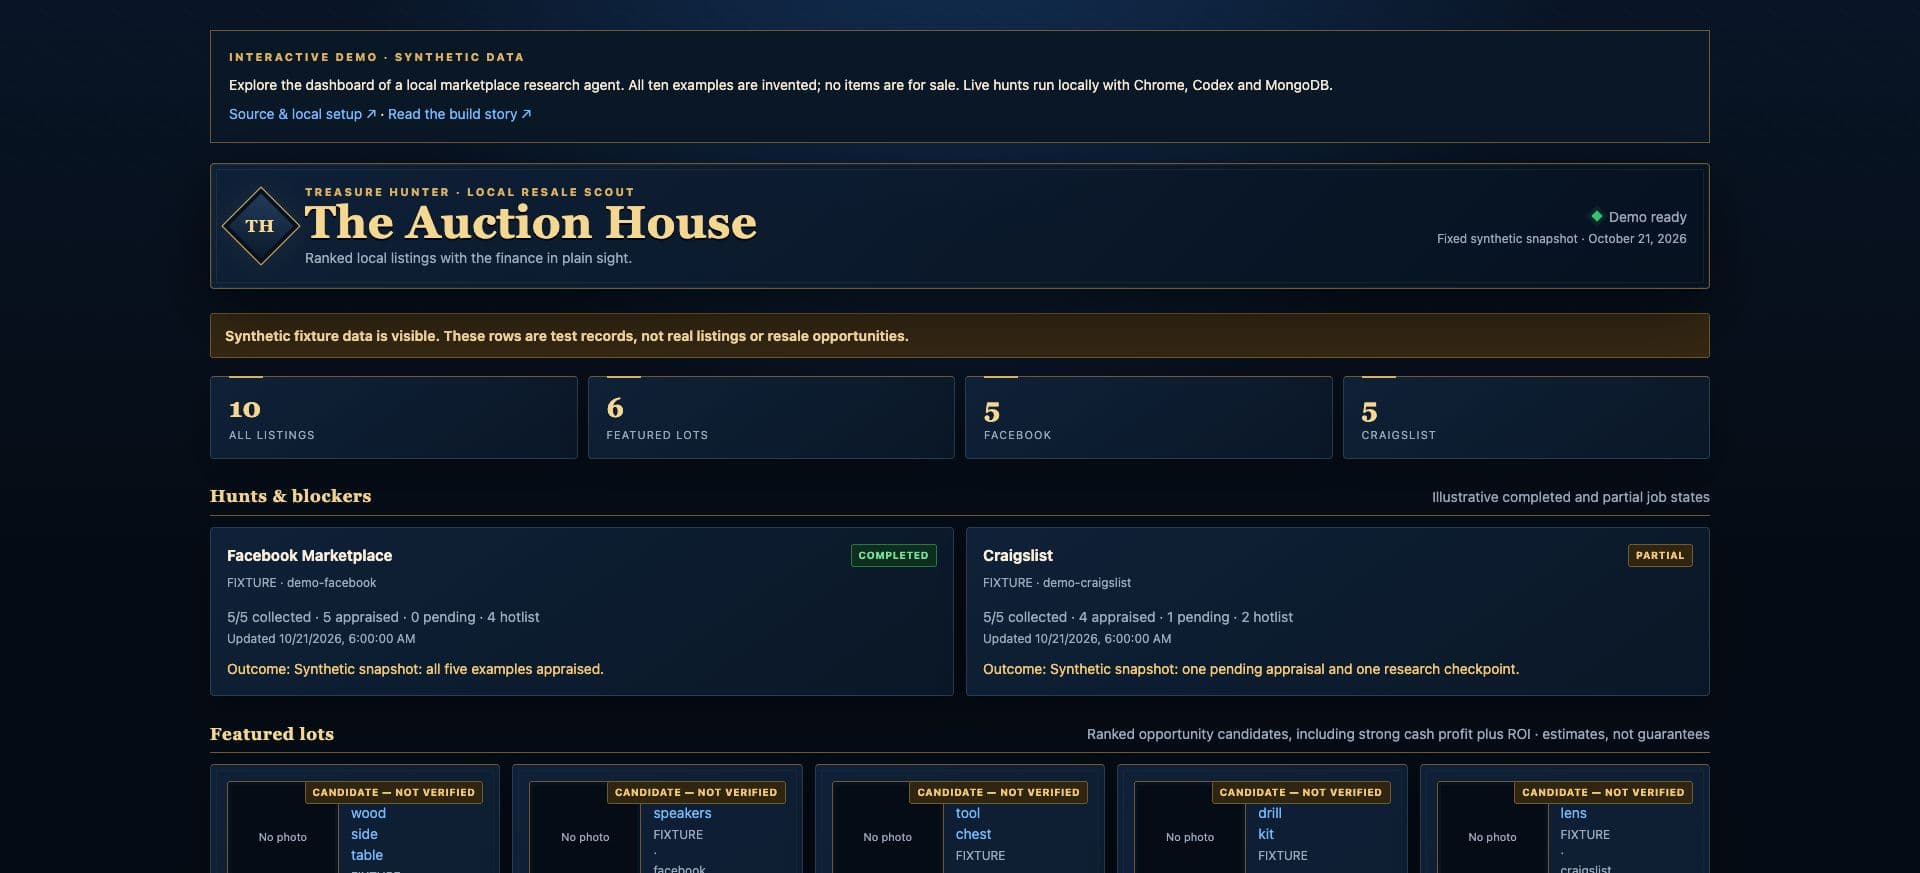
Treasure Hunter project screenshot

02 / Working system

Treasure Hunter

Creator and engineer · Local agent system

A local, chat-operated marketplace agent that values every collected item, persists evidence and checkpoints, and explains its ranked results in a live dashboard.

Chapter 03 / Field notes

Writing from the work

Conceptual editorial study of embossed terrain and printing plates
Concept study / Ideas made durable
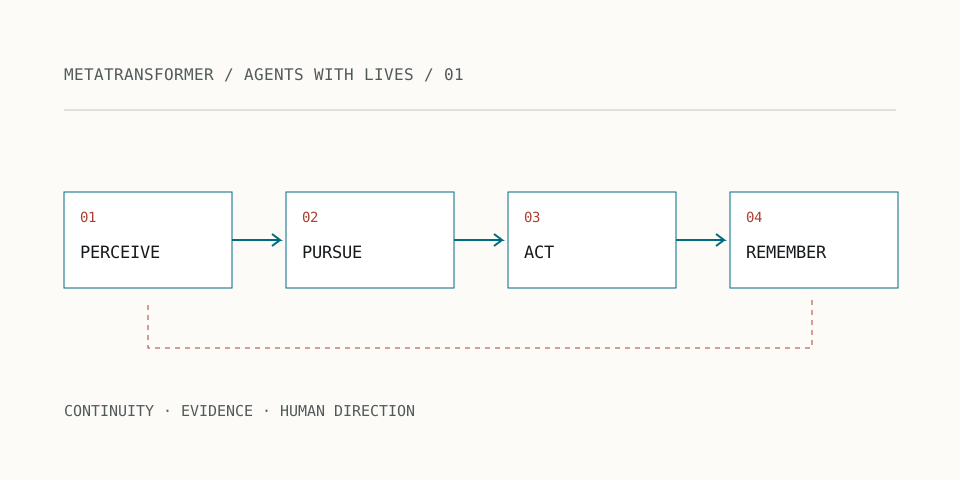
  1. Give Agents Lives, Not Just Jobs

    A1

    Give Agents Lives, Not Just Jobs

    Why I think ongoing pursuits, embodied experience, and a limited point of view can give agents something more interesting to say.

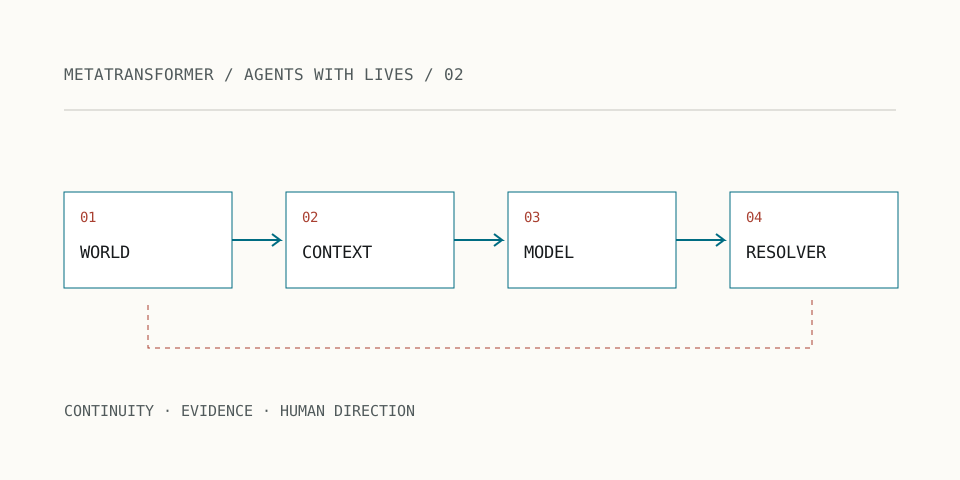
  2. A Small Model With a World Around It

    A2

    A Small Model With a World Around It

    What my local-model companion experiments taught me about structured output, useful conversation, and the architecture around a model.

  3. Human–Agent Interaction Is More Than Chat

    A3

    Human–Agent Interaction Is More Than Chat

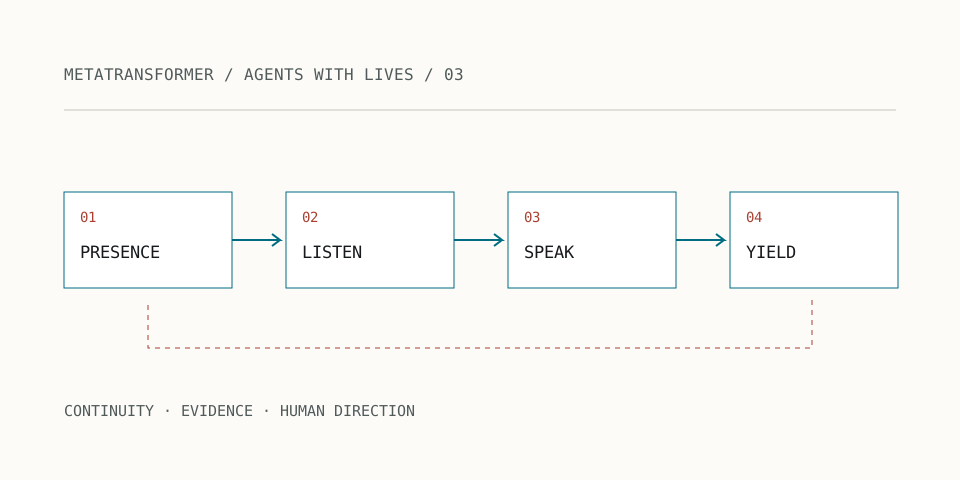
    Presence, silence, interruption, and selective memory are part of the interface when an agent has a continuing life.

  4. Digital Twins Need More Than Your Chat History

    A4

    Digital Twins Need More Than Your Chat History

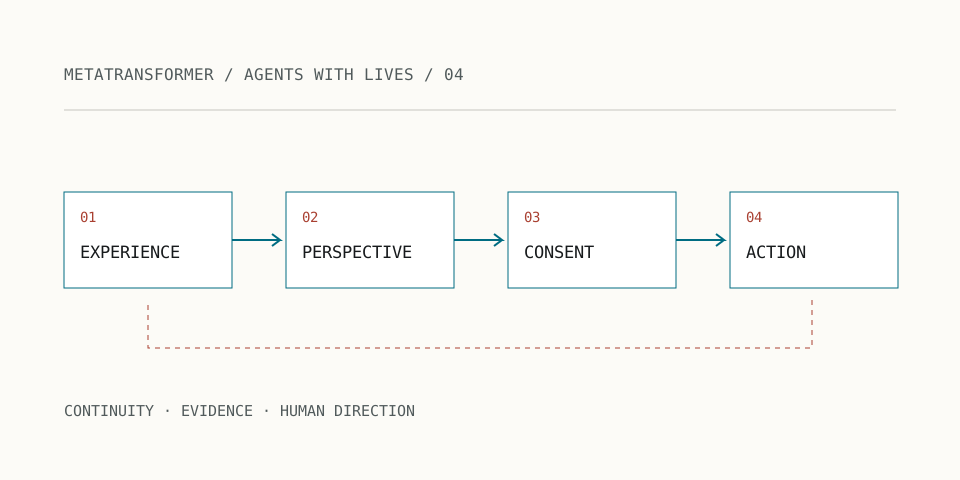
    A useful twin needs a history of changing views, explicit authority, and a distinction between representing someone and becoming its own agent.

  5. Marketing Is a World Agents Can Work In

    A5

    Marketing Is a World Agents Can Work In

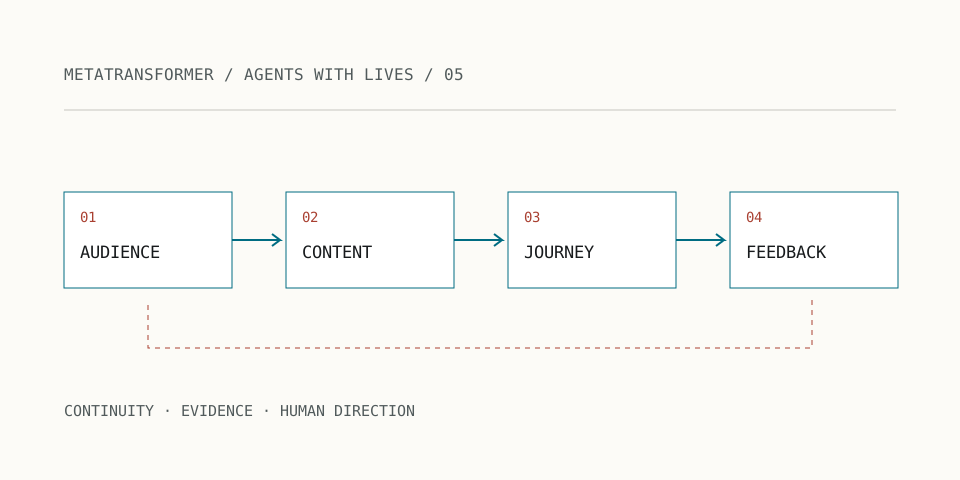
    Lessons from SFV and SMBIN: content, audiences, campaigns, and feedback form an environment an agent can understand.

  6. Treasure Hunter

    01

    Treasure Hunter

    Building an agent that values every item and exposes its evidence, uncertainty, and resumable state.

  7. AI Robot Workshop

    02

    AI Robot Workshop

    From a plausible agent answer to persistent project files, explicit evidence, and a buildable path.

  8. Fractal Authoring

    03

    Fractal Authoring

    Building The Lower Worlds Online, and a world that can keep becoming more specific.

  9. Building procedural environments in Valenfeld

    04

    Building procedural environments in Valenfeld

    A practical look at shaping generated terrain into a world with authored intent.

  10. The Transformer Is the Transistor

    05

    The Transformer Is the Transistor

    A thesis on AI as a building block, and the verification and coordination infrastructure models need around them.

  11. The Lower Worlds: Awakening

    06

    The Lower Worlds: Awakening

    Building a home worth returning to: a playable Godot adventure, with in-engine screenshots and source.

Chapter 04 / About

Builder,
end to end.

Portrait of Nick Bryant

I’ve spent most of my career taking an idea and building the whole thing: the prototype, the product, and the team. Web, mobile, games, AR/VR, AI—I like learning what a hard problem needs and getting it working.

Right now I’m deep into agentic programming and generative worlds, trying to build things that weren’t practical a few years ago.

Denver / Boulder

Selected work

ARCOS / VN.AI

IP workflows · Next.js / Supabase / MongoDB / Redis / AWS

I led product engineering for IP management, permitted-use workflows, and content analysis. We connected roughly twenty model integrations and supported product pilots across the application and cloud stack.

Selected work

Procurement Sciences

B2B software · MERN / Python / FastAPI

I rebuilt an early Rails prototype as a MERN and Python/FastAPI product. I implemented the application, managed the engineering team, and hired the incoming CTO before the handoff.

Current · advisory

Investing systems

Investing / syndication · Co-founder, now advisory

I built investing and syndication software, AI-assisted underwriting workflows, investor reporting, and marketing automation for SMB Investor Network and Search Fund Ventures. My current role is passive advisory work.

2015–2020

Interesting Inventions

Consumer apps & games · Technical co-founder

Built and launched 5+ consumer applications through a holding-company portfolio, reaching nine-figure revenue scale.
Full career on the resume ↗
Projects
Editorial illustration

Proposed project book

Choose your next obsession.

24 briefs to explore, adapt, or replace with a project of your own.

Each brief names what you’ll make, learn, and test. The four core builds are suggested starting points. Your own projects are welcome from day one.

Explore the project briefs

Filter by level

24 of 24 briefs

CoreSoftwareBrief 01

Robot mission control

Build a browser dashboard that streams a camera, charts motor telemetry, and sends bounded commands to a bench rig. Add user accounts, saved runs, and a deployment another student can use.

Skills: TypeScript and React, APIs and data storage, Streaming, Testing

Open project brief
CoreManipulationBrief 02

Teach an arm by example

Assemble an SO-101 leader/follower pair. Record demonstrations of sorting objects, train an imitation policy with LeRobot, and compare it with a scripted baseline.

Skills: CAD fixtures, Calibration, Python datasets, Model training

Open project brief
CoreEmbodied AIBrief 03

Give Reachy a personality

Build a Reachy Mini app that turns toward a person, answers questions about its camera view, and performs a small set of deliberate gestures. Connect speech, vision, and a language model.

Skills: Audio and video pipelines, Async Python, Tool calling, State machines

Open project brief
CoreAutonomyBrief 04

A rover that finds its way

Build a wheeled rover, model it in simulation, and use ROS 2 to map a room and navigate between marked stations. Add a browser mission screen and run history.

Skills: Motor control, Encoders, Sensor fusion, ROS 2 mapping

Open project brief
ElectiveSpatial ComputingBrief 05

Move a robot with your hand

Make an AR interface that overlays a planned path and lets a person position a virtual gripper with hand tracking. Map approved motions to a real arm only after simulation.

Skills: 3D transforms, Hand tracking, Inverse kinematics, Networking

Open project brief
ElectiveAerial RoboticsBrief 06

Build and program a quadcopter

Assemble a small quadcopter, understand its power and flight-control systems, then program a waypoint mission in PX4 simulation.

Skills: Airframe assembly, ESCs and IMUs, Control and telemetry, Simulation

Open project brief
ElectiveMechanical DesignBrief 07

A gripper you designed

Design interchangeable fingers for irregular objects. Print three versions and compare grip reliability, payload, and deformation on the same test set.

Skills: CAD, Tolerances, Materials, Motor sizing and force measurement

Open project brief
ElectiveVision and LanguageBrief 08

An arm that understands requests

Ask for a known object by name. A vision system identifies it and a language model selects from tested robot actions, while motion limits and execution checks remain outside the model.

Skills: Perception, Structured outputs, Task planning, Bounded controls

Open project brief
ElectiveDeveloper ToolsBrief 09

The robot failure replay tool

Record camera frames, commands, and sensor values on one timeline. Build a replay interface that lets another engineer inspect the seconds before a failed grasp.

Skills: Timestamps, Storage schemas, Playback and visualization, APIs

Open project brief
ElectiveML InfrastructureBrief 10

A dataset worth sharing

Build a collection and review tool for robot demonstrations. Flag missing frames, poor views, and inconsistent labels before training starts.

Skills: Data validation, Video indexing, Annotation UX, Python

Open project brief
ElectiveMotion ControlBrief 11

Precision drawing machine

Build a pen plotter or adapt an arm to draw repeatable patterns. Calibrate the workspace and compensate for mechanical error.

Skills: Kinematics, Trajectory planning, Backlash, Calibration

Open project brief
ElectiveMachine VisionBrief 12

A robot that sorts your parts

Build a tabletop sorting cell for a fixed set of workshop parts using a camera, small arm, and custom trays. Write the operator interface.

Skills: Lighting, Camera calibration, Classification, System integration

Open project brief
ElectiveEnergy and EmbeddedBrief 13

Instrument a tiny energy system

Build a low-voltage solar test rig that logs power under changing light and load. Compare fixed and motor-tracked panel positions in controlled conditions.

Skills: Voltage and current sensing, Calibration, Motor control, Time-series data

Open project brief
ElectiveScientific InstrumentsBrief 14

Automate a bench experiment

Build a motorized camera stage that repeatedly photographs a non-biological sample at known positions. Add a web scheduler and searchable experiment records.

Skills: Precision motion, Optics, Calibration, Experiment software

Open project brief
ElectiveNetworked SystemsBrief 15

Robot telepresence from a browser

Drive a rover through a low-speed course from a remote browser with video, command acknowledgments, and an independent stop control.

Skills: WebRTC, Command queues, Latency, Connection recovery

Open project brief
StretchMulti-Robot SystemsBrief 16

Two robots share a job

Have a rover deliver a tray to a stationary arm. Use a shared task queue and explicit handoff signals to coordinate the sequence.

Skills: Coordination, State machines, Docking, Distributed systems

Open project brief
ElectiveSimulationBrief 17

Predict motion with a digital twin

Model an existing build, identify parameters from measurements, and use the simulation to predict a change before making it on hardware.

Skills: System identification, Physics simulation, Experiment design

Open project brief
ElectiveEmbedded HardwareBrief 18

A custom electronics board

Replace a messy prototype harness with a low-voltage sensor or interface board. Design the schematic, lay out the PCB, and bring it up on the bench.

Skills: Circuit design, PCB layout, Connectors and soldering, Debugging

Open project brief
ElectiveHuman-Robot InteractionBrief 19

Build a hand-motion instrument

Prototype a sensor glove that measures finger motion and drives a small gripper. Add calibration, a visible clutch mode, and a session viewer.

Skills: Wearable sensing, Filtering, Ergonomics, Motion mapping

Open project brief
ElectiveAI Product EngineeringBrief 20

Search a robot's memory

Index recorded robot sessions so a user can find moments such as failed picks or blocked routes. Link every answer back to the source clip.

Skills: Embeddings, Retrieval, Video metadata, Evaluation and frontend

Open project brief
StretchAerial PerceptionBrief 21

Vision-guided drone landing

Use a visual landing marker to estimate relative pose and approach a target in simulation. Consider transfer only after a supervised test plan is approved.

Skills: Camera geometry, Pose estimation, Flight-control integration

Open project brief
ElectiveIndustrial AutomationBrief 22

A miniature automated line

Build a low-voltage tabletop conveyor with object sensing, a sorting gate, and an operator screen. Implement the sequence in a PLC trainer or software PLC.

Skills: Ladder logic, Interlocks, Sensors and machine states, Operator UX

Open project brief
ElectivePlatform EngineeringBrief 23

Ship an update to a robot fleet

Create versioned deployments for two simulated robots and one bench device. Track software versions and roll back a bad release.

Skills: Containers, Continuous integration, Configuration and deployment, Observability

Open project brief
CapstoneFounder TrackBrief 24

Your own robotics product

Choose a specific user, interview them, and build a narrow product using the studio's hardware and software work. Test the resulting prototype with that user.

Skills: Product discovery, System architecture, Integration, Iteration

Open project brief

Choose a scope that fits your interests and the shared skills. Hardware, courses, compute, tools, and access are budgeted separately and confirmed before enrollment. The illustrations show build directions, not specific kits or completed member work.

See how the projects fit the year